

News


How Can a Quadruped Robot Automate Routine Industrial Inspection?
Industrial inspection is often repetitive, time-consuming, and difficult to scale. In a large factory, power plant, energy facility, or infrastructure site, inspection teams may need to follow the same routes, check the same equipment, record similar data, and repeat the process every day or every week.
Not every inspection task requires a person to physically walk through the entire site.
This is where Quadruped Robots can provide a practical option for inspection automation. By combining four-legged mobility with autonomous navigation and different inspection sensors, a quadruped robot can perform selected routine inspection tasks, collect data, and allow operators to monitor site conditions remotely.
The goal is not to replace human inspectors. Instead, the robot can take over repetitive data-collection and patrol tasks, while people remain responsible for analysis, decisions, maintenance, and tasks that require human judgment.
Why Automate Routine Industrial Inspection?
Traditional inspection is still essential for many industrial operations. However, routine manual patrols can create several challenges.
Repetitive inspection routes
Many inspection tasks require personnel to visit the same locations repeatedly.
For example, an operator may need to:
- Check equipment indicators
- Inspect pipelines and machinery
- Observe operating conditions
- Record temperatures or other readings
- Check for visible abnormalities
- Monitor specific areas of a facility
When these tasks are repeated frequently, a significant amount of working time can be spent simply walking between inspection points and collecting routine information.
A mobile robot can perform some of these repetitive tasks according to predefined inspection routes.
Large inspection areas
Industrial facilities can cover large areas and may include multiple floors, outdoor sections, equipment rooms, corridors, and other areas.
A quadruped robot can be programmed to patrol specific areas and collect data at predefined inspection points. This can help inspection teams focus their time on tasks that require professional judgment rather than routine movement and observation.
Difficult or uneven terrain
Industrial environments are not always designed for Wheeled Robots.
Stairs, ramps, uneven surfaces, small obstacles, and changes in elevation can make mobile inspection more difficult.
One of the main advantages of a quadruped platform is its ability to maintain mobility across certain types of uneven terrain and stairs. Research and commercial deployments have demonstrated the use of quadruped robots for inspection and data collection in complex industrial and construction environments.
However, terrain capability depends on the specific robot, environment, payload, and operating conditions. A site assessment is still necessary before deployment.
What Can a Quadruped Robot Actually Do During an Inspection?
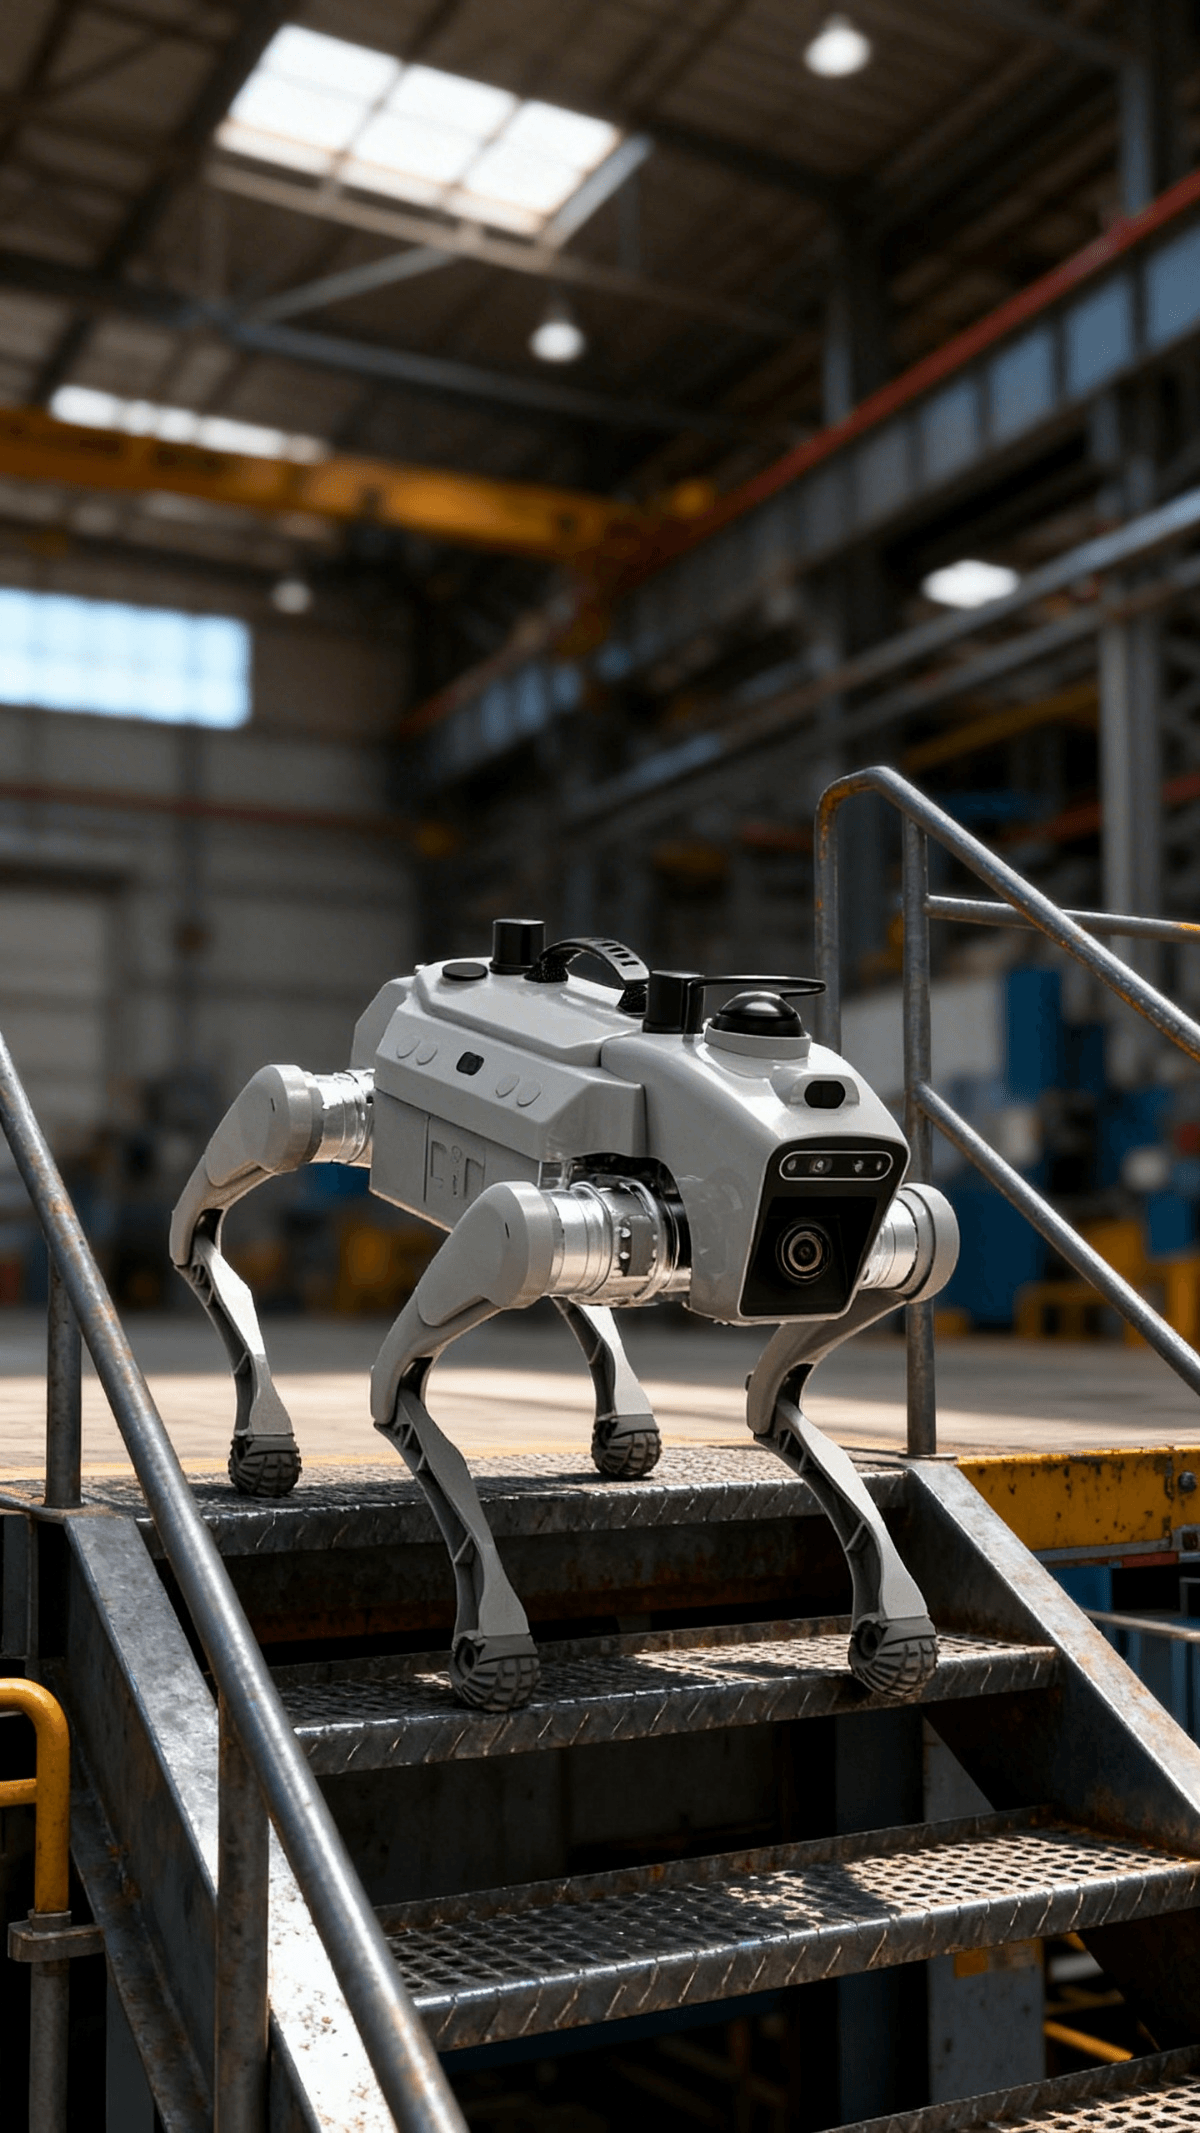
A quadruped robot is not simply a camera mounted on four legs. An industrial inspection platform can combine mobility, navigation, communication, and different sensing technologies according to the requirements of the application.
The exact capabilities depend on the robot model and payload configuration.
- Autonomous Navigation
Autonomous navigation is one of the basic capabilities required for routine Robotic Inspection.
A robot can use technologies such as LiDAR, cameras, IMU, SLAM, or other positioning technologies to understand its environment, build or use an existing map, and navigate between inspection points.
A typical mission may include:
Mapping → Route Planning → Autonomous Navigation → Inspection → Data Collection → Remote Review
This allows the robot to repeat a defined inspection route without requiring an operator to manually control every movement.
Industrial quadruped platforms available today commonly combine autonomous navigation with mapping, obstacle avoidance, and inspection missions.
- Visual Inspection
Cameras are among the most widely used inspection payloads.
A robot can capture images or video of:
- Equipment
- Pipes
- Valves
- Gauges
- Electrical components
- Production areas
- Structural conditions
- Other predefined inspection points
The collected visual information can then be reviewed by an operator or processed by a suitable software system.
This can make inspection records more consistent because the robot can return to the same locations and capture data using predefined routes and viewpoints.
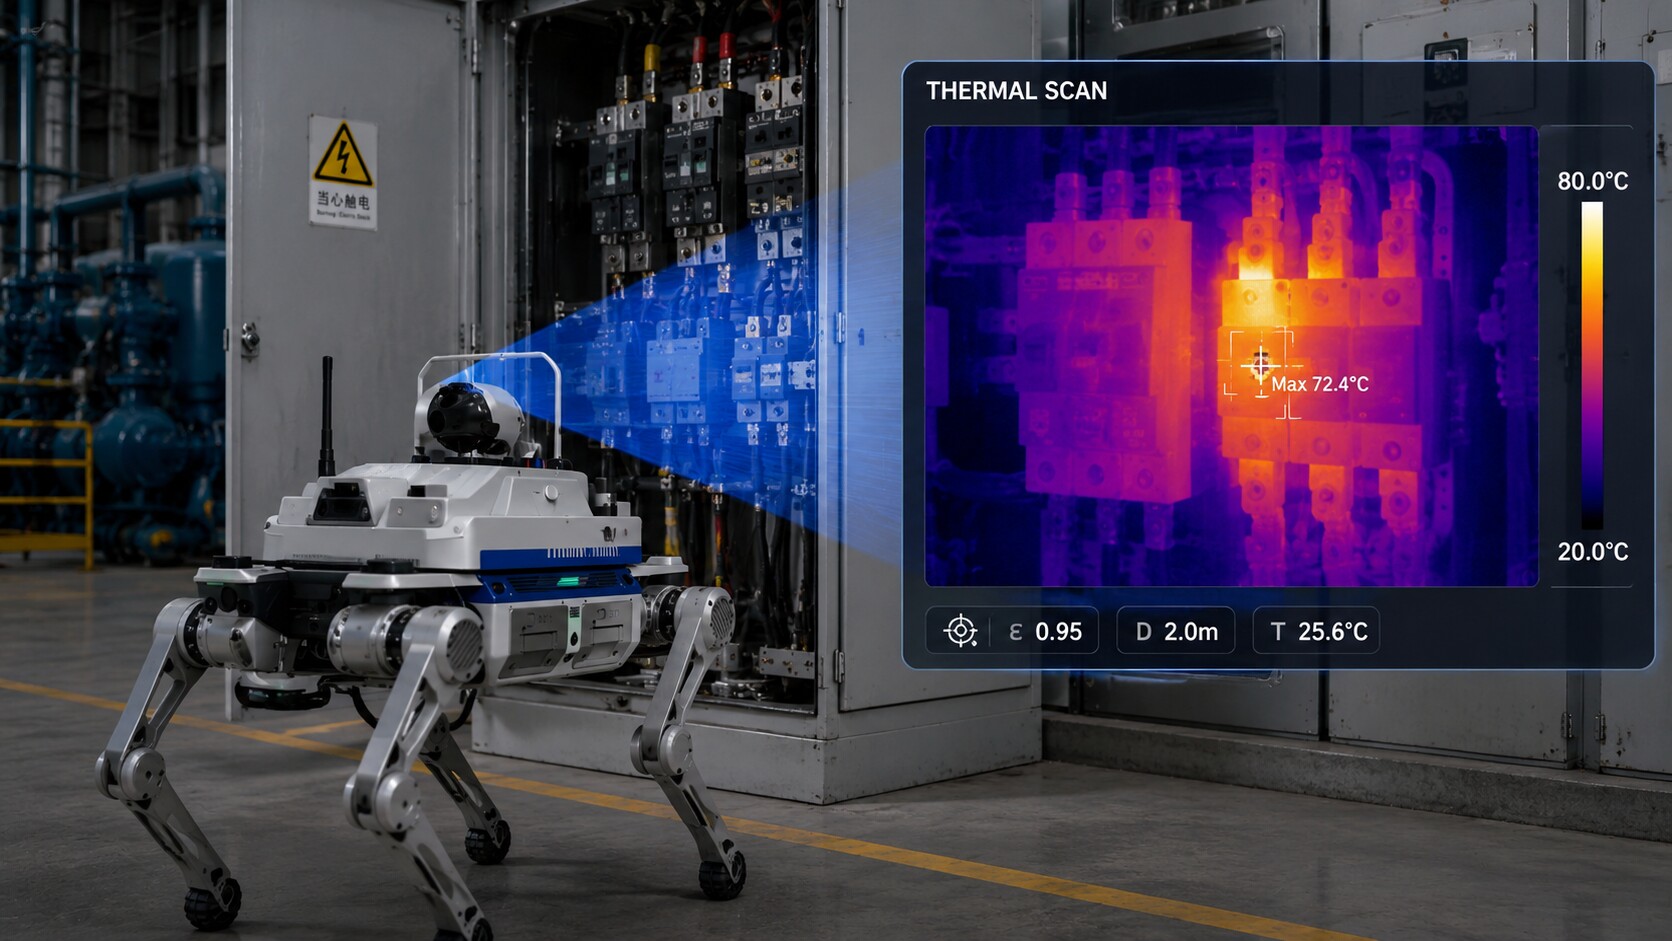
- Thermal Inspection
Thermal cameras can add another layer of information beyond normal visible-light images.
Temperature differences can sometimes provide early indications of abnormal equipment conditions, electrical problems, overheating components, insulation issues, or other conditions that may not be obvious from a standard camera image.
Several industrial quadruped inspection platforms use thermal sensors together with visual and navigation systems for equipment monitoring.
It is important to note that thermal imaging does not automatically mean that a robot can diagnose equipment failures. In many applications, the thermal data is used to identify areas that require further analysis or human verification.
- Gas Detection
For applications where environmental monitoring is required, a quadruped robot can potentially carry appropriate gas sensors.
Depending on the sensor configuration, robots can be used to monitor specific gases or environmental conditions while moving through predefined areas.
This can be particularly useful when inspection teams need to collect environmental data at multiple locations.
However, gas detection capability depends on the specific sensor, detection range, response characteristics, calibration, and application requirements. The robot itself should not be treated as a substitute for a complete industrial safety system.
- Remote Monitoring
A robot can also act as a mobile remote observation platform.
Through wireless communication and real-time video transmission, an operator can monitor the robot's surroundings without physically following the entire patrol route.
Depending on the system configuration, communication may use technologies such as Wi-Fi, 4G, or 5G.
This can be useful when inspection personnel need to supervise a robot operating in a large or difficult-to-access area.
How Does an Autonomous Robot Inspection Mission Work?
A practical inspection deployment usually involves several steps.
Step 1: Map the Inspection Area
The robot first needs to understand the environment in which it will operate.
Depending on the navigation system, LiDAR, cameras, IMU, SLAM, RTK, or other positioning technologies may be used to support mapping and localization.
Step 2: Define Inspection Points
The operator identifies the locations that need to be inspected.
For example:
- Equipment A
- Valve B
- Electrical cabinet C
- Pipeline section D
- Temperature monitoring point E
Not every location needs to be inspected in the same way.
Step 3: Create a Patrol Route
Inspection points can then be organized into a repeatable patrol route.
The route should take into account:
- Terrain
- Obstacles
- Access restrictions
- Communication coverage
- Required inspection time
- Robot battery capacity
- Sensor requirements
Step 4: Perform the Inspection
The robot moves along the planned route and collects data using its onboard sensors and inspection payloads.
Depending on the application, this may include visual images, video, thermal information, environmental measurements, or other sensor data.
Step 5: Review the Data
The collected information can then be transmitted to or accessed by an operator.
The operator can review the data and determine whether additional inspection or maintenance is required.
This human-in-the-loop approach is important for practical industrial deployment.
The robot can automate movement and data collection, while human personnel remain responsible for interpreting important findings and making operational decisions.
Quadruped Robot vs. Traditional Wheeled Inspection Robot
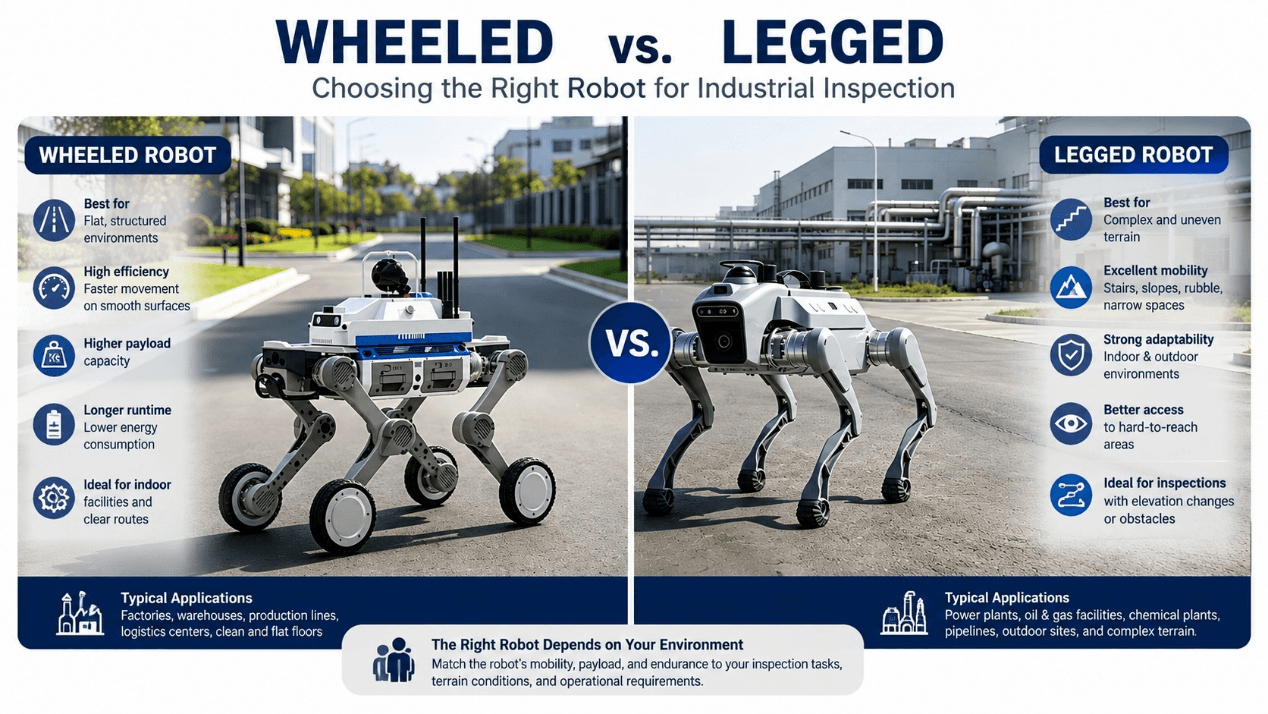
The right mobile robot depends on the environment.
Wheeled robots can be highly effective on flat, structured surfaces and may provide advantages in speed, efficiency, and payload capacity for certain applications.
Quadruped robots become more interesting when the inspection environment includes:
- Stairs
- Uneven terrain
- Ramps
- Small obstacles
- Changes in elevation
- Outdoor areas with less predictable surfaces
This does not mean a quadruped robot is always better.
If a facility has smooth, flat floors and simple routes, a wheeled AMR may be a more efficient solution.
The key question is therefore not:
“Which robot is more advanced?”
The better question is:
“Which mobile platform matches the actual inspection environment?”
This distinction is important.
The value of a robot is not necessarily that it can perform every task independently. In many industrial applications, the greater value comes from allowing the robot to perform predictable and repetitive work while human experts focus on higher-value decisions.
When Does a Quadruped Robot Make Sense?
A quadruped inspection robot may be worth evaluating when a site has several of the following characteristics:
- Frequent routine inspections
- Large inspection areas
- Repetitive patrol routes
- Uneven or challenging terrain
- Stairs or changes in elevation
- A need for remote monitoring
- Multiple inspection sensors
- A requirement to collect inspection data consistently
- Areas where reducing unnecessary personnel exposure is beneficial
On the other hand, a quadruped robot may not be the best choice for every application.
For example, extremely narrow spaces, highly specialized maintenance tasks, or environments requiring specific hazardous-area certifications may require different solutions.
Certification is particularly important when considering deployment in hazardous or potentially explosive environments. A robot should only be used in such areas when its certifications and technical specifications meet the requirements of the specific site and application.
What Should You Evaluate Before Deploying an Inspection Robot?
Before selecting a quadruped robot, customers should consider more than the robot's walking ability.
A practical evaluation should include:
Inspection Area
How large is the area that needs to be inspected?
Terrain
Are there stairs, slopes, uneven ground, obstacles, or other mobility challenges?
Inspection Tasks
What exactly needs to be checked?
Visual inspection? Thermal monitoring? Gas detection? Data collection?
Inspection Frequency
How often does the robot need to patrol?
Once a day? Several times a day? Continuously?
Mission Duration
How long does one inspection mission need to last?
Battery capacity and charging strategy should be evaluated according to the actual route and payload.
Communication
Is stable Wi-Fi available? Is 4G or 5G required? Are there areas with weak signal coverage?
Payload
Which sensors or inspection equipment need to be carried?
Environmental Conditions
Temperature, dust, water exposure, lighting conditions, and terrain can all affect robot performance.
Human Intervention
Which tasks should be fully autonomous, and when should an operator take control?
Answering these questions before purchasing a robot can help prevent a common mistake: selecting a robot based mainly on its specifications rather than on the actual inspection workflow.
A Practical Approach to Robot Inspection
The most effective industrial robot projects usually start with a specific problem rather than with the robot itself.
Instead of asking:
“What can this robot do?”
Start with:
“Which inspection tasks are repetitive, measurable, and suitable for automation?”
For example, if an operator currently spends several hours every day walking through a facility to visually check the same equipment, a robot may be able to automate part of that process.
If the inspection also requires temperature monitoring or environmental sensing, appropriate sensors can be added to the platform.
The result is not necessarily a completely autonomous factory.
It can simply be a more efficient inspection workflow:
Human expertise + robotic mobility + sensor data + remote monitoring
That is where quadruped robots can provide practical value.
Conclusion
Quadruped robots are becoming a practical option for selected industrial inspection applications.
Their combination of legged mobility, autonomous navigation, cameras, thermal imaging, gas sensing, communication systems, and other payloads allows them to perform different types of routine inspection and data-collection tasks.
However, successful deployment depends on matching the robot to the actual site.
A good inspection robot is not simply the robot with the longest battery life or the largest number of sensors. It is the platform that can reliably perform the required tasks under the site's terrain, environmental, communication, and operational conditions.
For companies evaluating quadruped robots for industrial inspection, the best starting point is to define the inspection area, terrain, required tasks, inspection frequency, mission duration, and sensor requirements.
If you are evaluating a quadruped robot for industrial inspection, share your inspection environment, terrain conditions, required inspection tasks, and expected patrol duration with our team. We can help you evaluate whether a quadruped platform is suitable for your application and recommend an appropriate configuration.